
01 · AT REST
Everything free, 3 s of simulation
All joints released and every body simulated for 3 seconds.
- Asset pairs overlapping > 2 mm
- 0
- Bodies moving on their own
- 0
- Joints drifting
- 0
- Food items, all with mass
- 17
Sample build report · internal lab demo
Every delivery comes with a short report like this one: what we measured from your data, what we had to assume, and how the physics checks went — including what didn’t pass. This one is from our own demo, built from 154 existing phone photos. Nobody from our team visited the site.
Full build after several revisions. A free 48 h sample is smaller: one space up to 300 m².
What came out
From the photos
Where the same point shows up in two or more photos, we triangulate it. That gives real distances without a scanner.
From the light fixtures. The office ceiling has two levels: 2.28 m and 2.43 m.
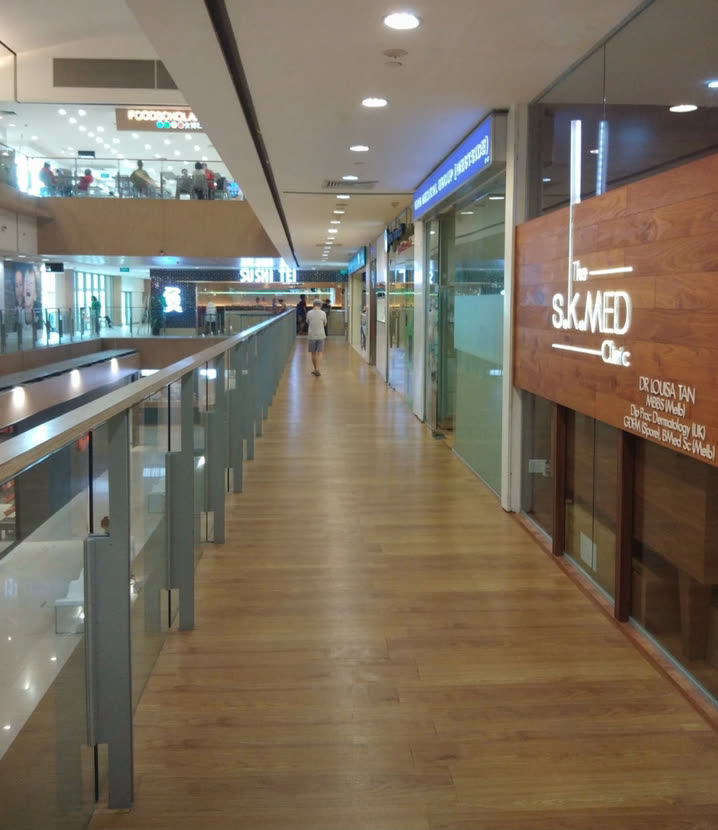
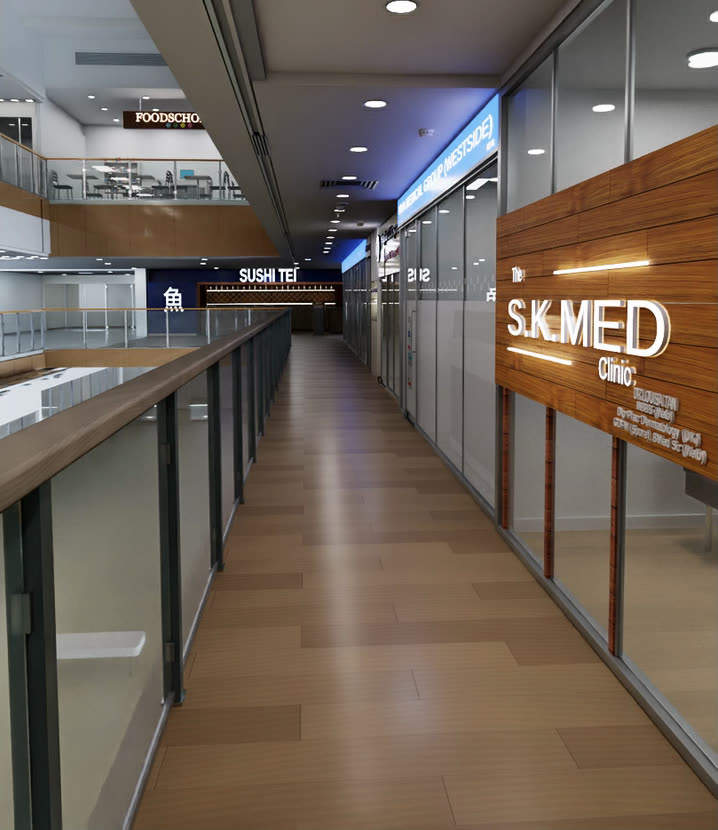
Positions and sizes. One shop sign was located from 10 photos, with error at or under 0.6 px.
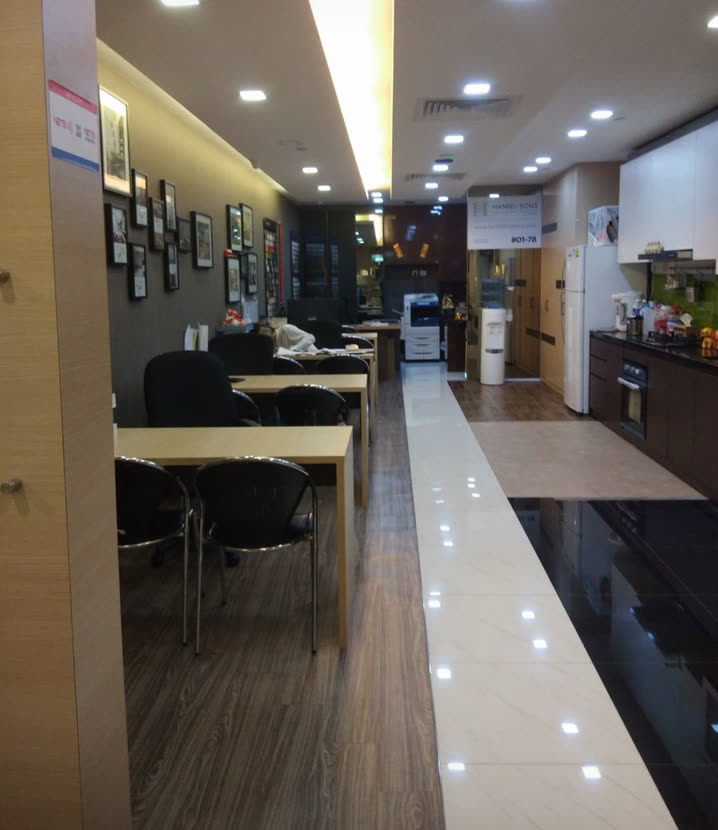
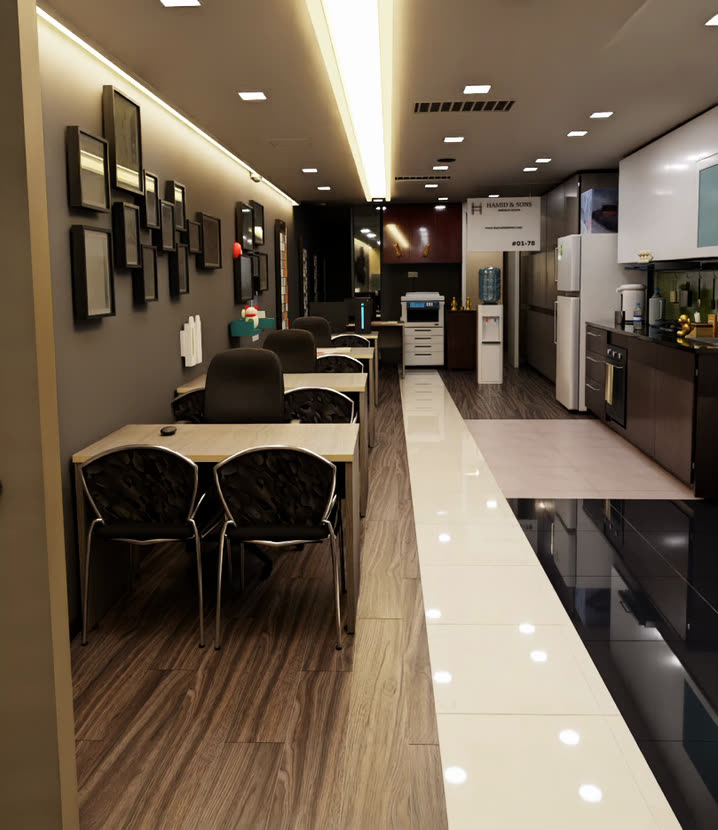
Desks, chairs, pantry, fridge, water dispenser, copier and cabinet heights. The copier and the wall outlet behind it were measured from 8 photos — which moved the copier 1.2 m forward from our first placement, right up to the grey wall with the outlet.
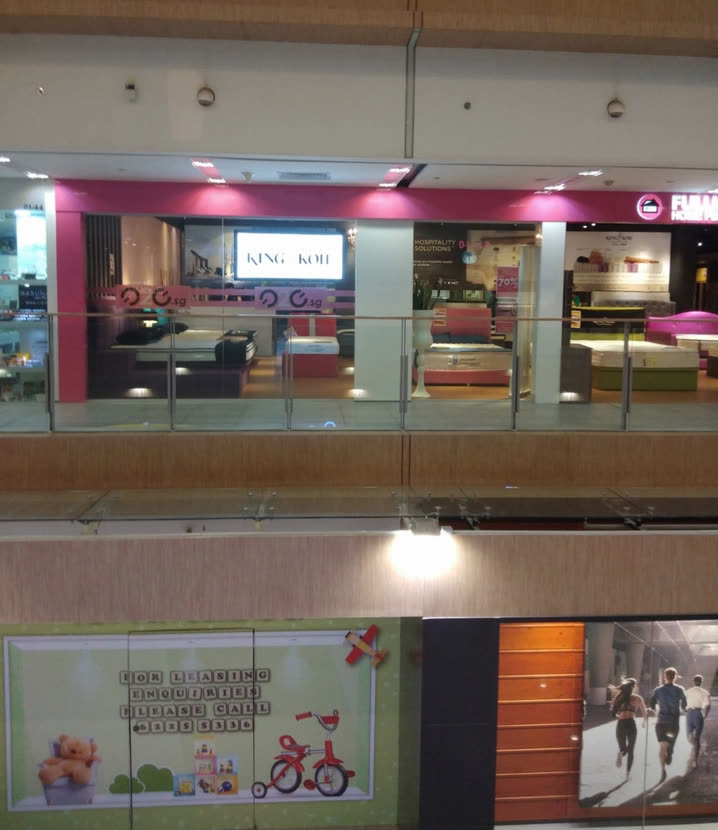
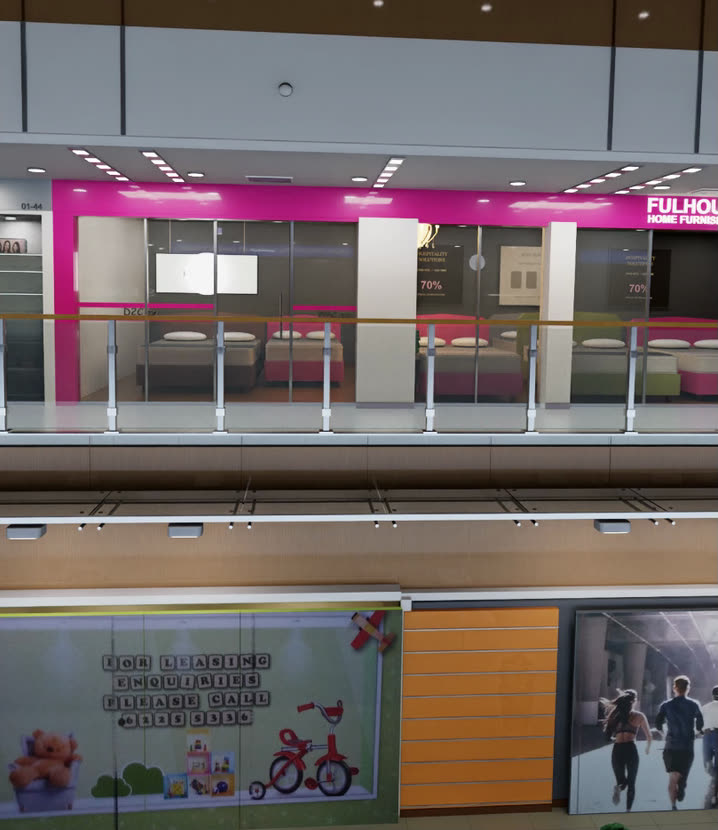
Positions of the walkway and shop faces.
We rendered the twin from each photo’s camera pose and matched floor, desk, tile and wall colours region by region, then applied the camera’s white balance.
Not in the photos
We keep these lists separate so you always know which parts are evidence and which are our best guess.
ASSUMED
CHANGED ON REQUEST
KNOWN DIFFERENCES
Physics checks
01 · AT REST
All joints released and every body simulated for 3 seconds.
02 · EVERY JOINT
Each of the 263 non-shutter joints was driven open and closed on its own. 255 reached at least 85% of their target. The 8 that didn’t are listed below with the reason.
Bottles in the door shelves slid at most 11 mm while the door swung; none fell. Fruit rides along when the crisper drawer is pulled out.
03 · ROBOT TASK
A dual-arm mobile manipulator drives in through the office door, pulls the fridge open by its handle, takes a bottle from the door shelf by friction, pushes the door shut and stands the bottle on a desk. No scripted object motion — only contact.
The door-shelf bottles rode the swinging door and stayed within 2 mm of it. The 2.5° is a milk carton that settled 1.6° onto its scanned, slightly uneven base at the start.
| Part | Opened | Why |
|---|---|---|
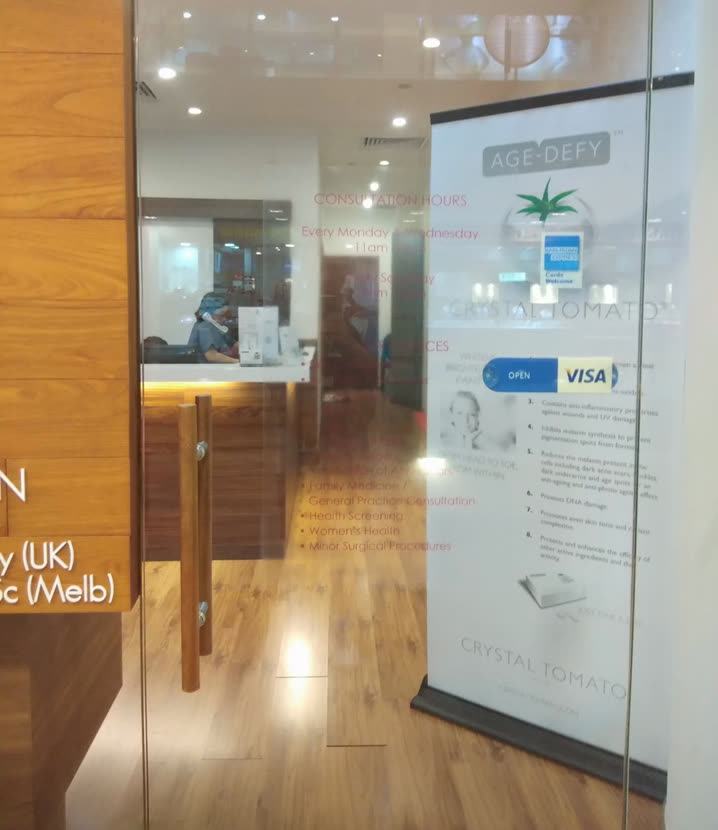
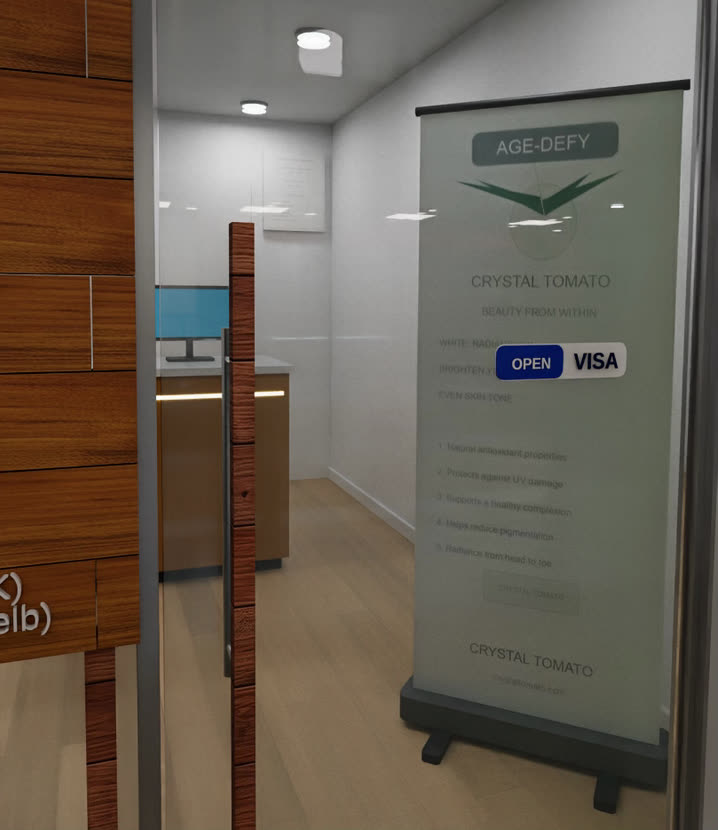
| Clinic entrance door | 79% | Heavy door, motor torque capped at 60 N·m, so 1 s wasn’t enough. Given 3 s it reaches 98% — and then touches a banner stand that is also in the photos. |
| Marble-front entrance door | 44% | Heavy door, same 60 N·m cap. Reaches its target given 3 s. |
| Fridge crisper drawer | 9% | Blocked by the closed fridge door — as it would be in real life. |
| Storage cabinet A, door 2 | 22% | Hits a hanging sign we measured from the photos. |
| Storage cabinet B, door 1 | 16% | Hits the corridor wall. |
| Storage cabinet B, door 2 | 16% | Hits the corridor wall. |
| Copier bypass tray | 69% | Hits the edge of the mirror behind it. The photos show the tray open, so our estimated hinge position is slightly off. |
| Task chair swivel | 84% | Hits the mirror behind it and a computer on the desk. |
Same camera, same pose
Left: the real photo. Right: the twin, rendered from that photo’s exact camera pose and field of view.
Send photos, a floor plan, a SLAM map or CAD. You get a sim-ready sample in 48 h, with a report like this one. First space free.